Geometric Vision and Robotics Lab
See the unseen, shape the shell 洞见未见,塑以躯壳
[ Team ]
Meet the Team
Shiyan Su
Monash University PhD Student
Wenzhuo Sun
Monash University PhD Student
Zhiyi Jiang
Monash-SEU joint PhD Student
Weishuai Song
Monash-SEU joint PhD Student
Shijian Wang
Monash-SEU joint PhD Student
Runhao Fu
Research Intern
Xingjian Wang
Research Intern
[ About The Team ]
We build intelligent visual systems that bridge embodied AI and clinical medicine.
Leveraging 3D scene understanding, multimodal agents, and geometry-aware reconstruction to advance spatial perception and interaction across surgical scenarios and digital twins.
[ Research Directions ]
Our Research Areas
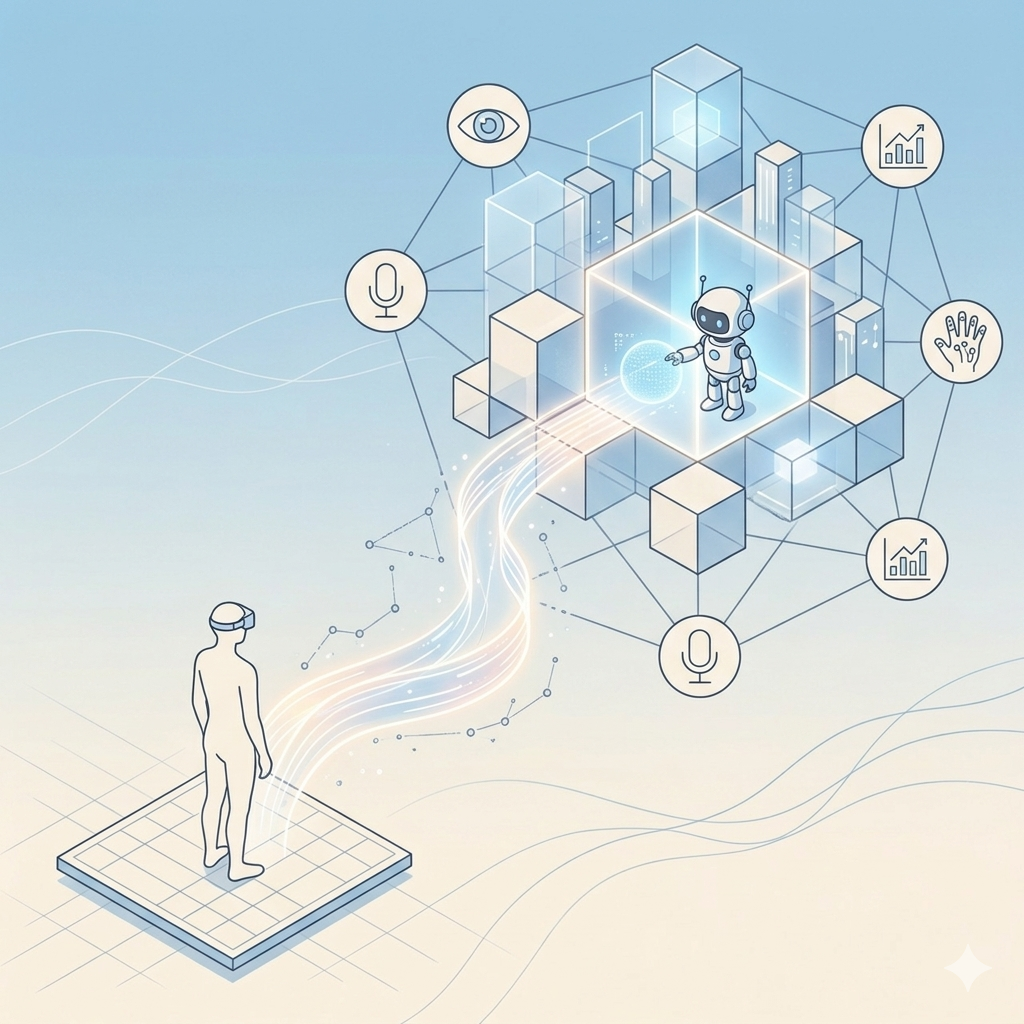
Multimodal World Model
Enables systems to perceive, interpret, and reason about dynamic scenes from videos and 3D representations.
Read more →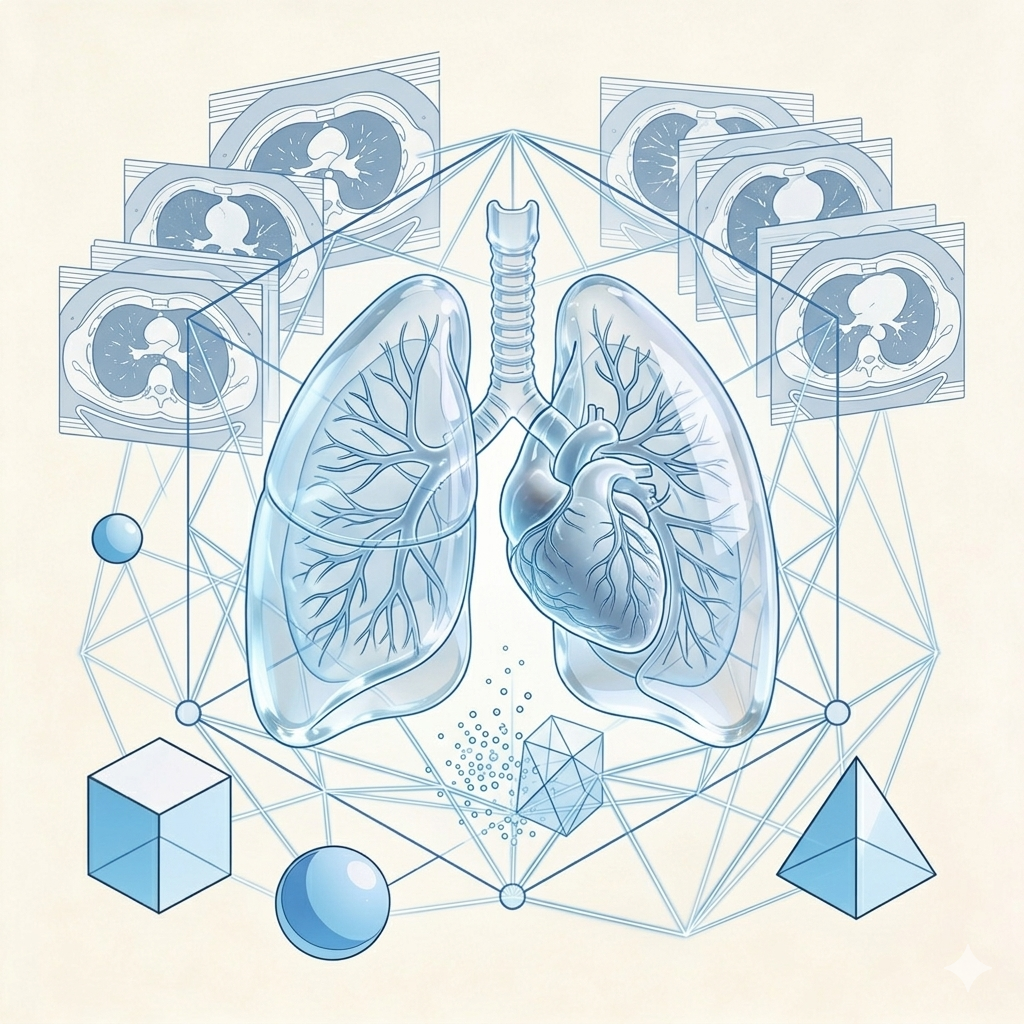
Geometry Estimation and 3D Reconstruction
Focuses on recovering accurate 3D geometry, depth, and structure from visual data, especially in medical scenarios.
Read more →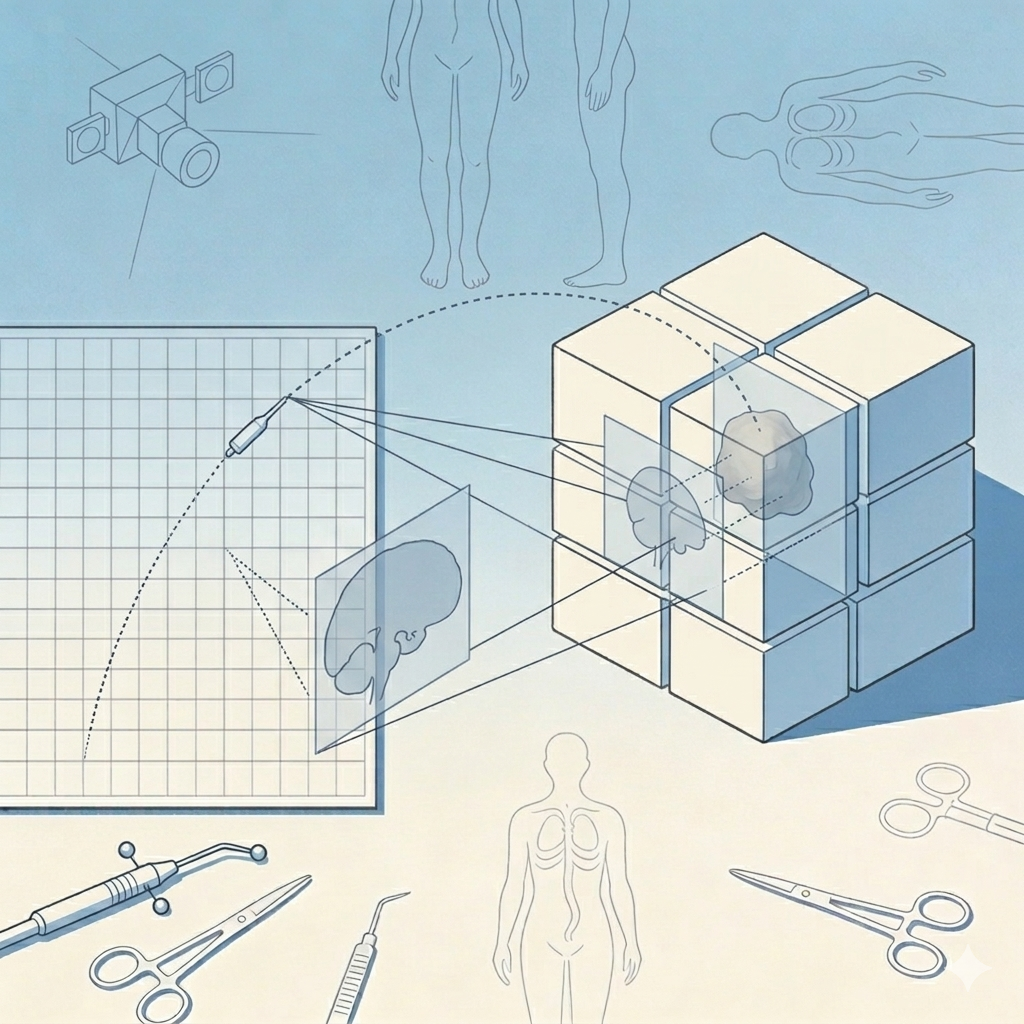
Registration
Studies robust alignment between 2D and 3D data to support precise applications such as surgical navigation.
Read more →
Digital Twins
Explores building virtual environments and multimodal intelligent systems for simulation and embodied interaction.
Read more →[ Publications ]
Featured Research Projects
Multimodal World Model
Enables systems to perceive, interpret, and reason about dynamic scenes from videos and 3D representations.

MuSEAgent: A Multimodal Reasoning Agent with Stateful Experiences
Conference Under Review
, et al.
Submitted to ECCV • 2026
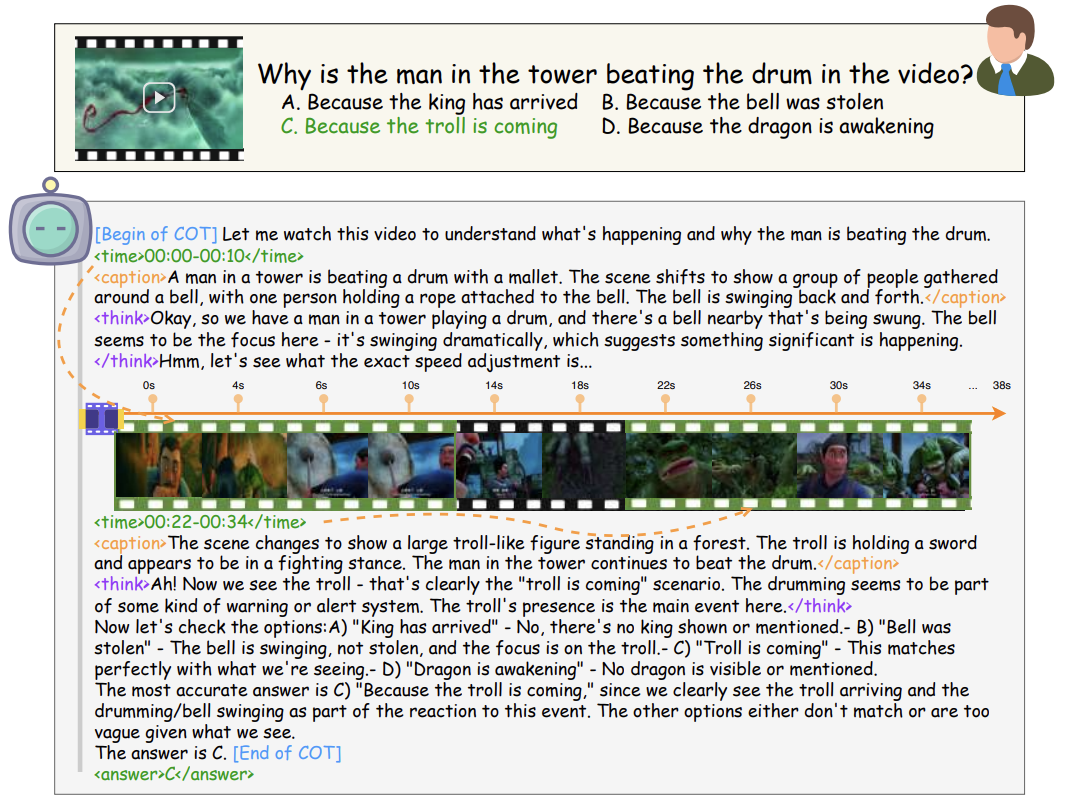
Video-Thinker: Sparking "Thinking with Videos" via Reinforcement Learning
Conference Under Review
, et al.
Submitted to ICML • 2026
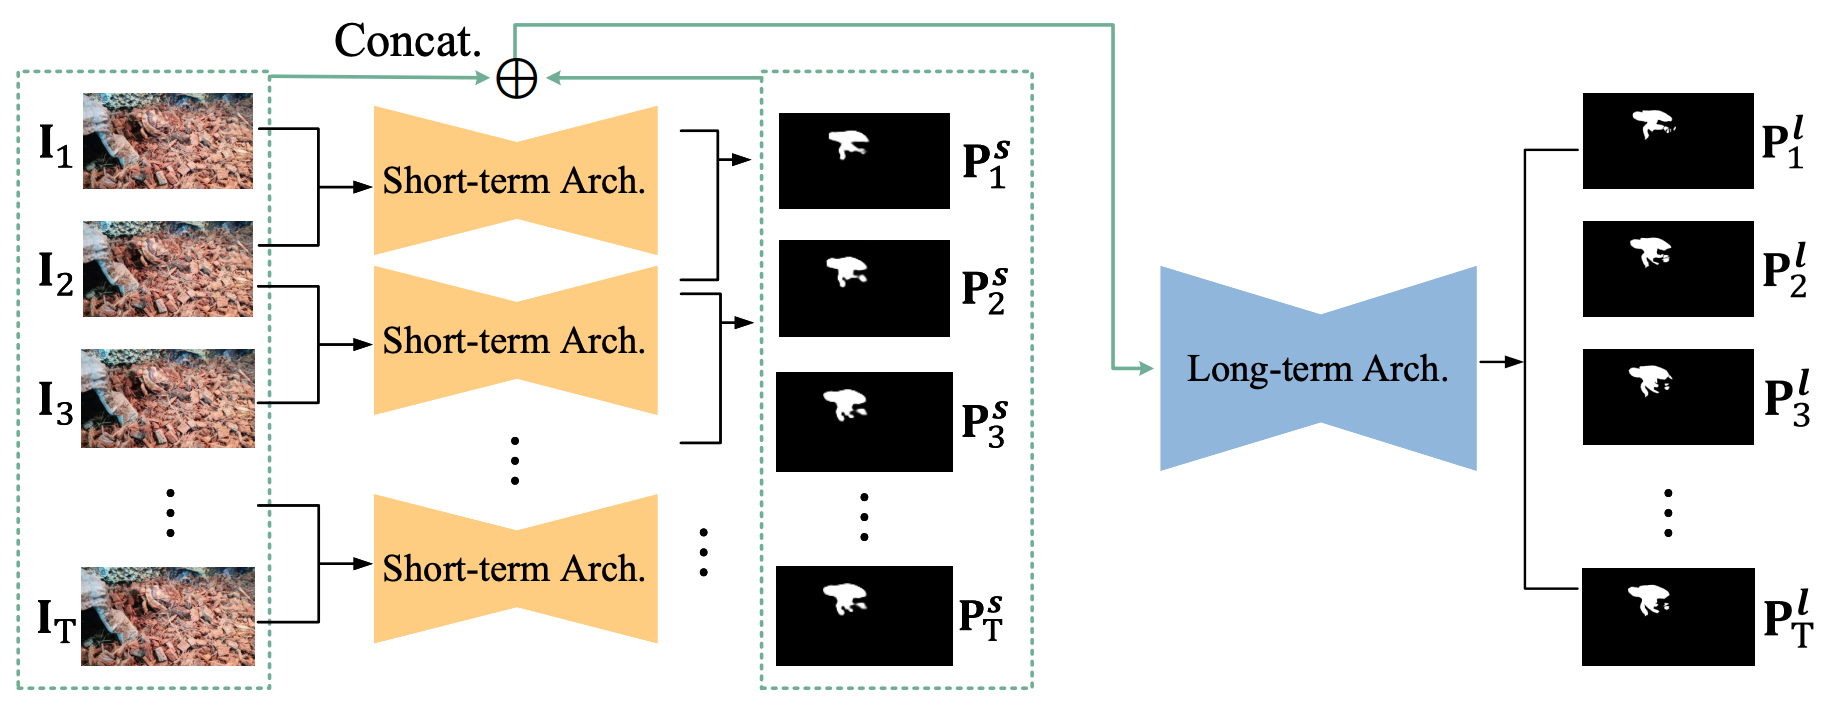
Implicit Motion Handling for Video Camouflaged Object Detection
Conference Accepted
, et al.
CVPR • 2022
Geometry Estimation and 3D Reconstruction
Focuses on recovering accurate 3D geometry, depth, and structure from visual data, especially in medical scenarios.
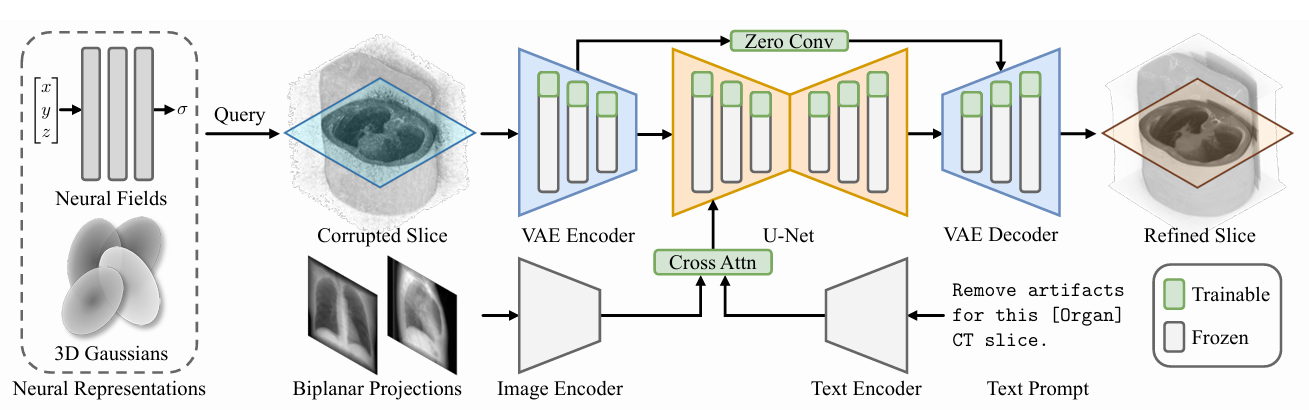
DiffNR: Diffusion-Enhanced Neural Representation Optimization for Sparse-View 3D Tomographic Reconstruction
Conference Accepted
, et al.
AAAI • 2026
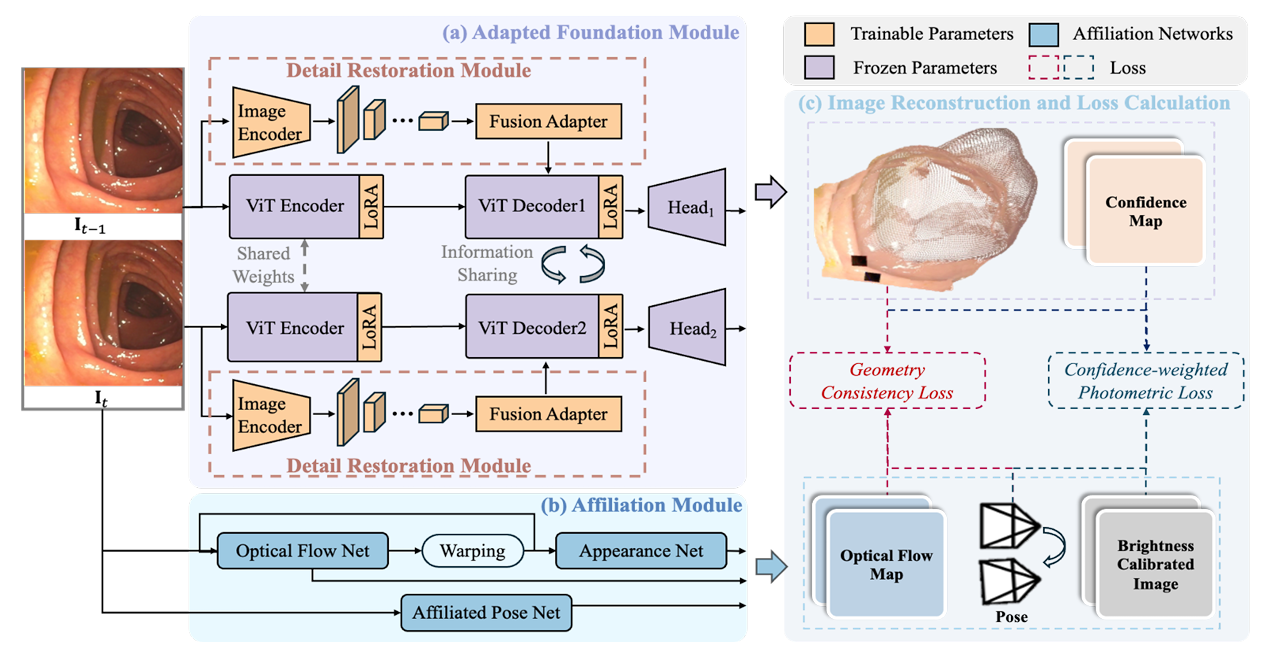
ColonAdapter: Geometry Estimation Through Foundation Model Adaptation for Colonoscopy
Journal Accepted
, et al.
IEEE Robotics and Automation Letters • 2025
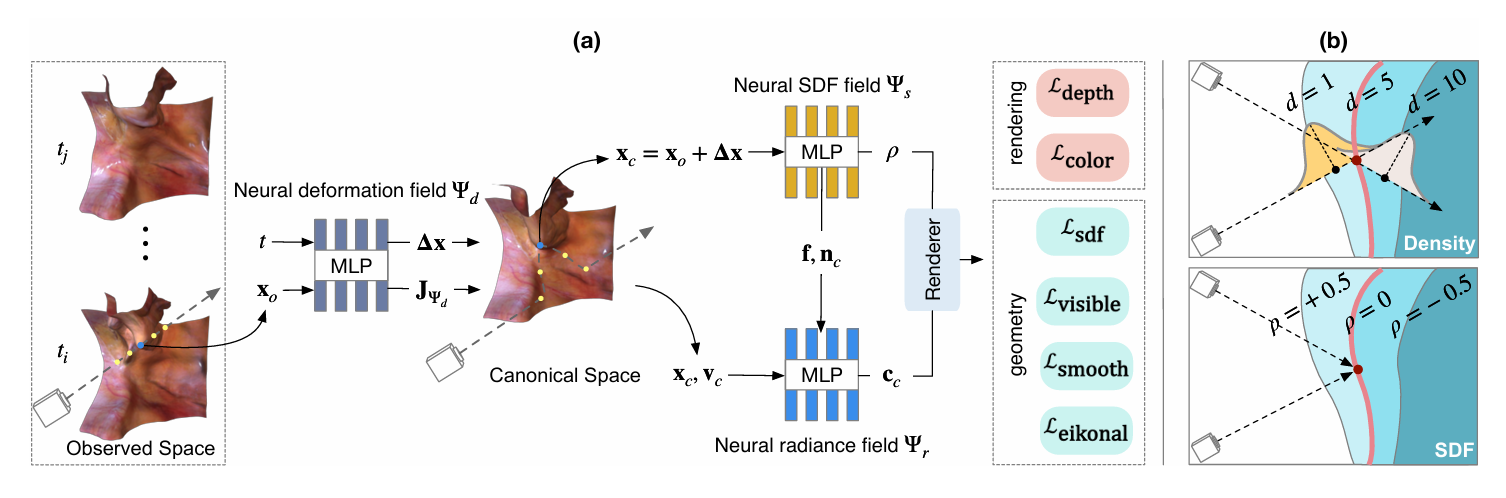
EndoSurf: Neural Surface Reconstruction of Deformable Tissues with Stereo Endoscope Videos
Conference Accepted
, et al.
MICCAI 2023 Oral, Student Travel Award, Top 3% • 2023
Digital Twins
Explores building virtual environments and multimodal intelligent systems for simulation and embodied interaction.
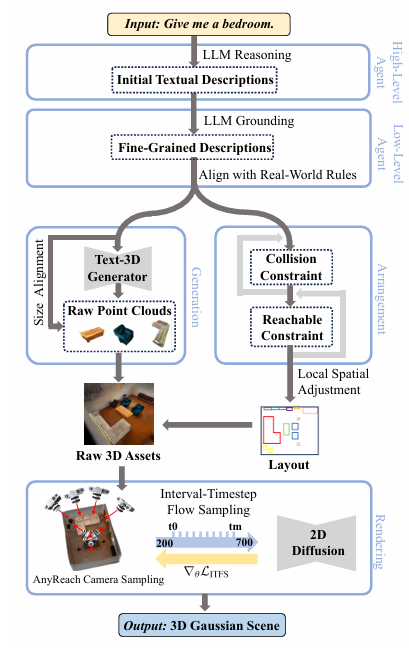
RoomPlanner: Explicit Layout Planner for Easier LLM-Driven 3D Room Generation
Conference Preprint
, et al.
Preprint • 2025